|
Débora Oliveira I'm Doctoral Researcher at the Artificial Intelligence and Robotics Lab in the University of Technology Nuremberg under Prof. Wolfram Burgard. I have a Master's degree in Robotics, Cognition and Intelligence from the Technical University of Munich and a Master's and Bachelor's degree in Electrical Enginnering from the Federal University of Campina Grande. I have a minor in microelectronics and a focus on computer vision and embedded systems.
|

|


Published Papers |
|
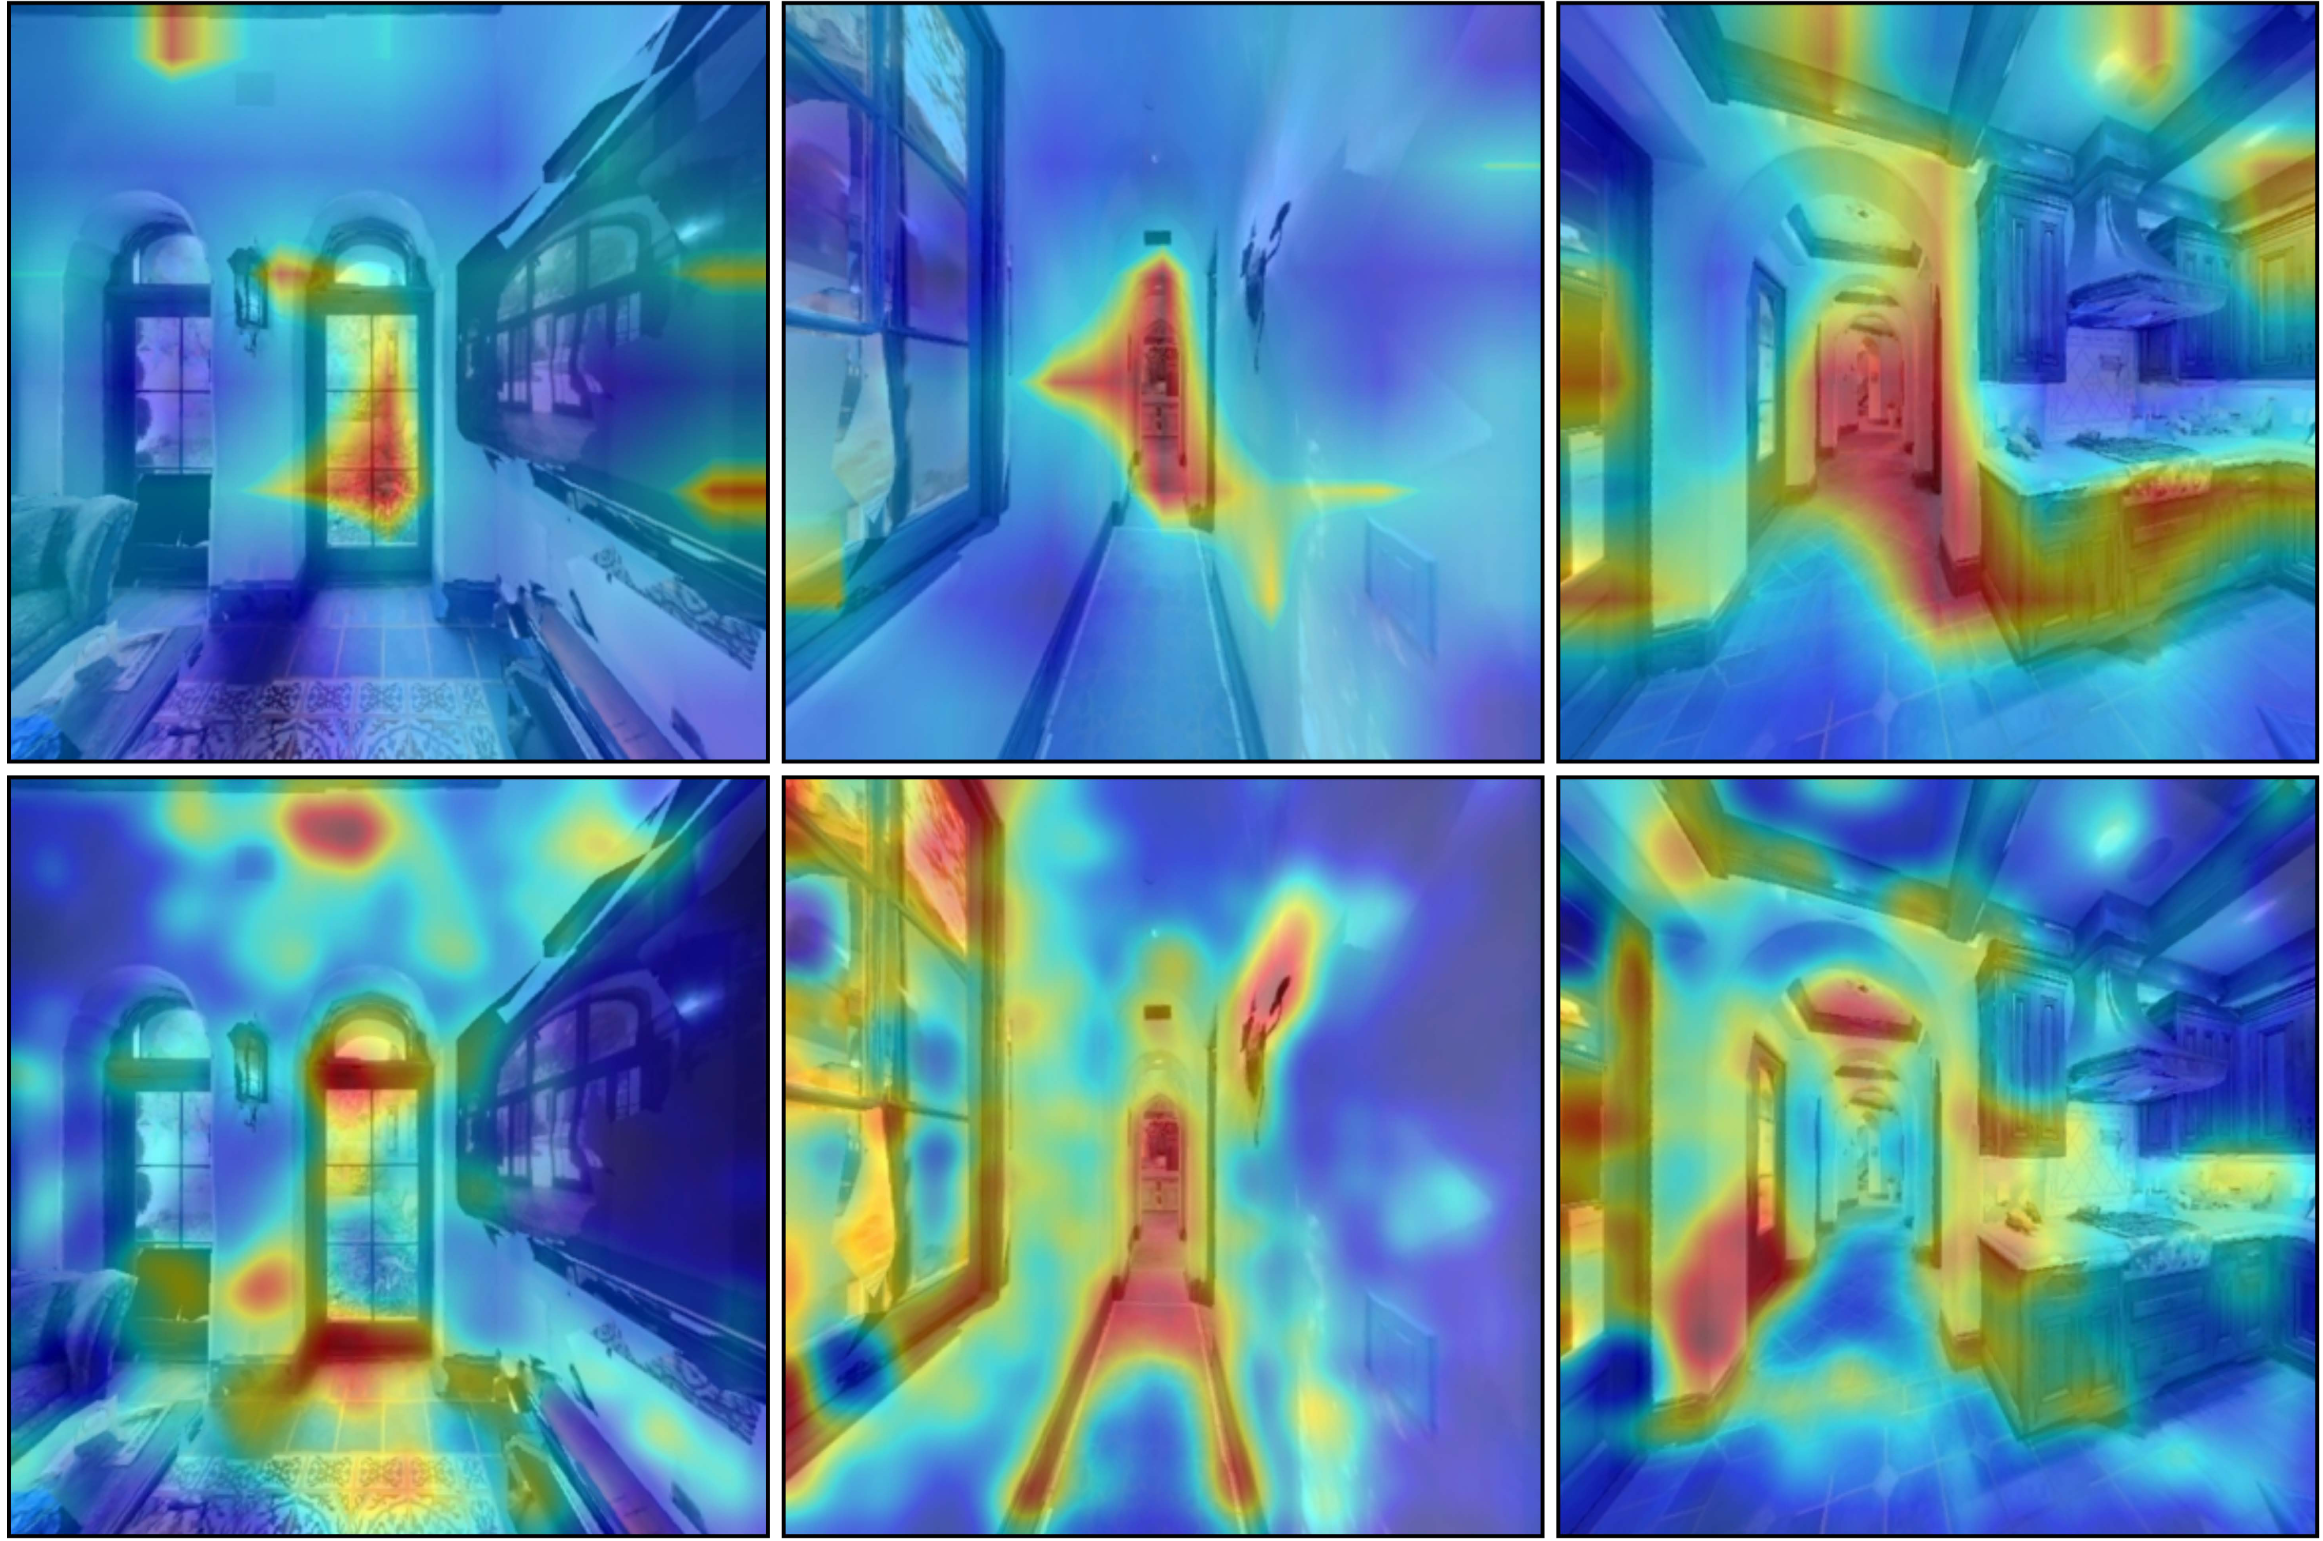
What do VLM-Based Vision-Language Navigation Models Rely on: Interpreting and Steering Policy Behavior Débora Oliveira*, Samiran Gode*, Abhijeet Nayak*, Marco Hutter, Cordelia Schmid, Lukas Rosemberg Schmid, Wolfram Burgard arXiv, 2026 |
|
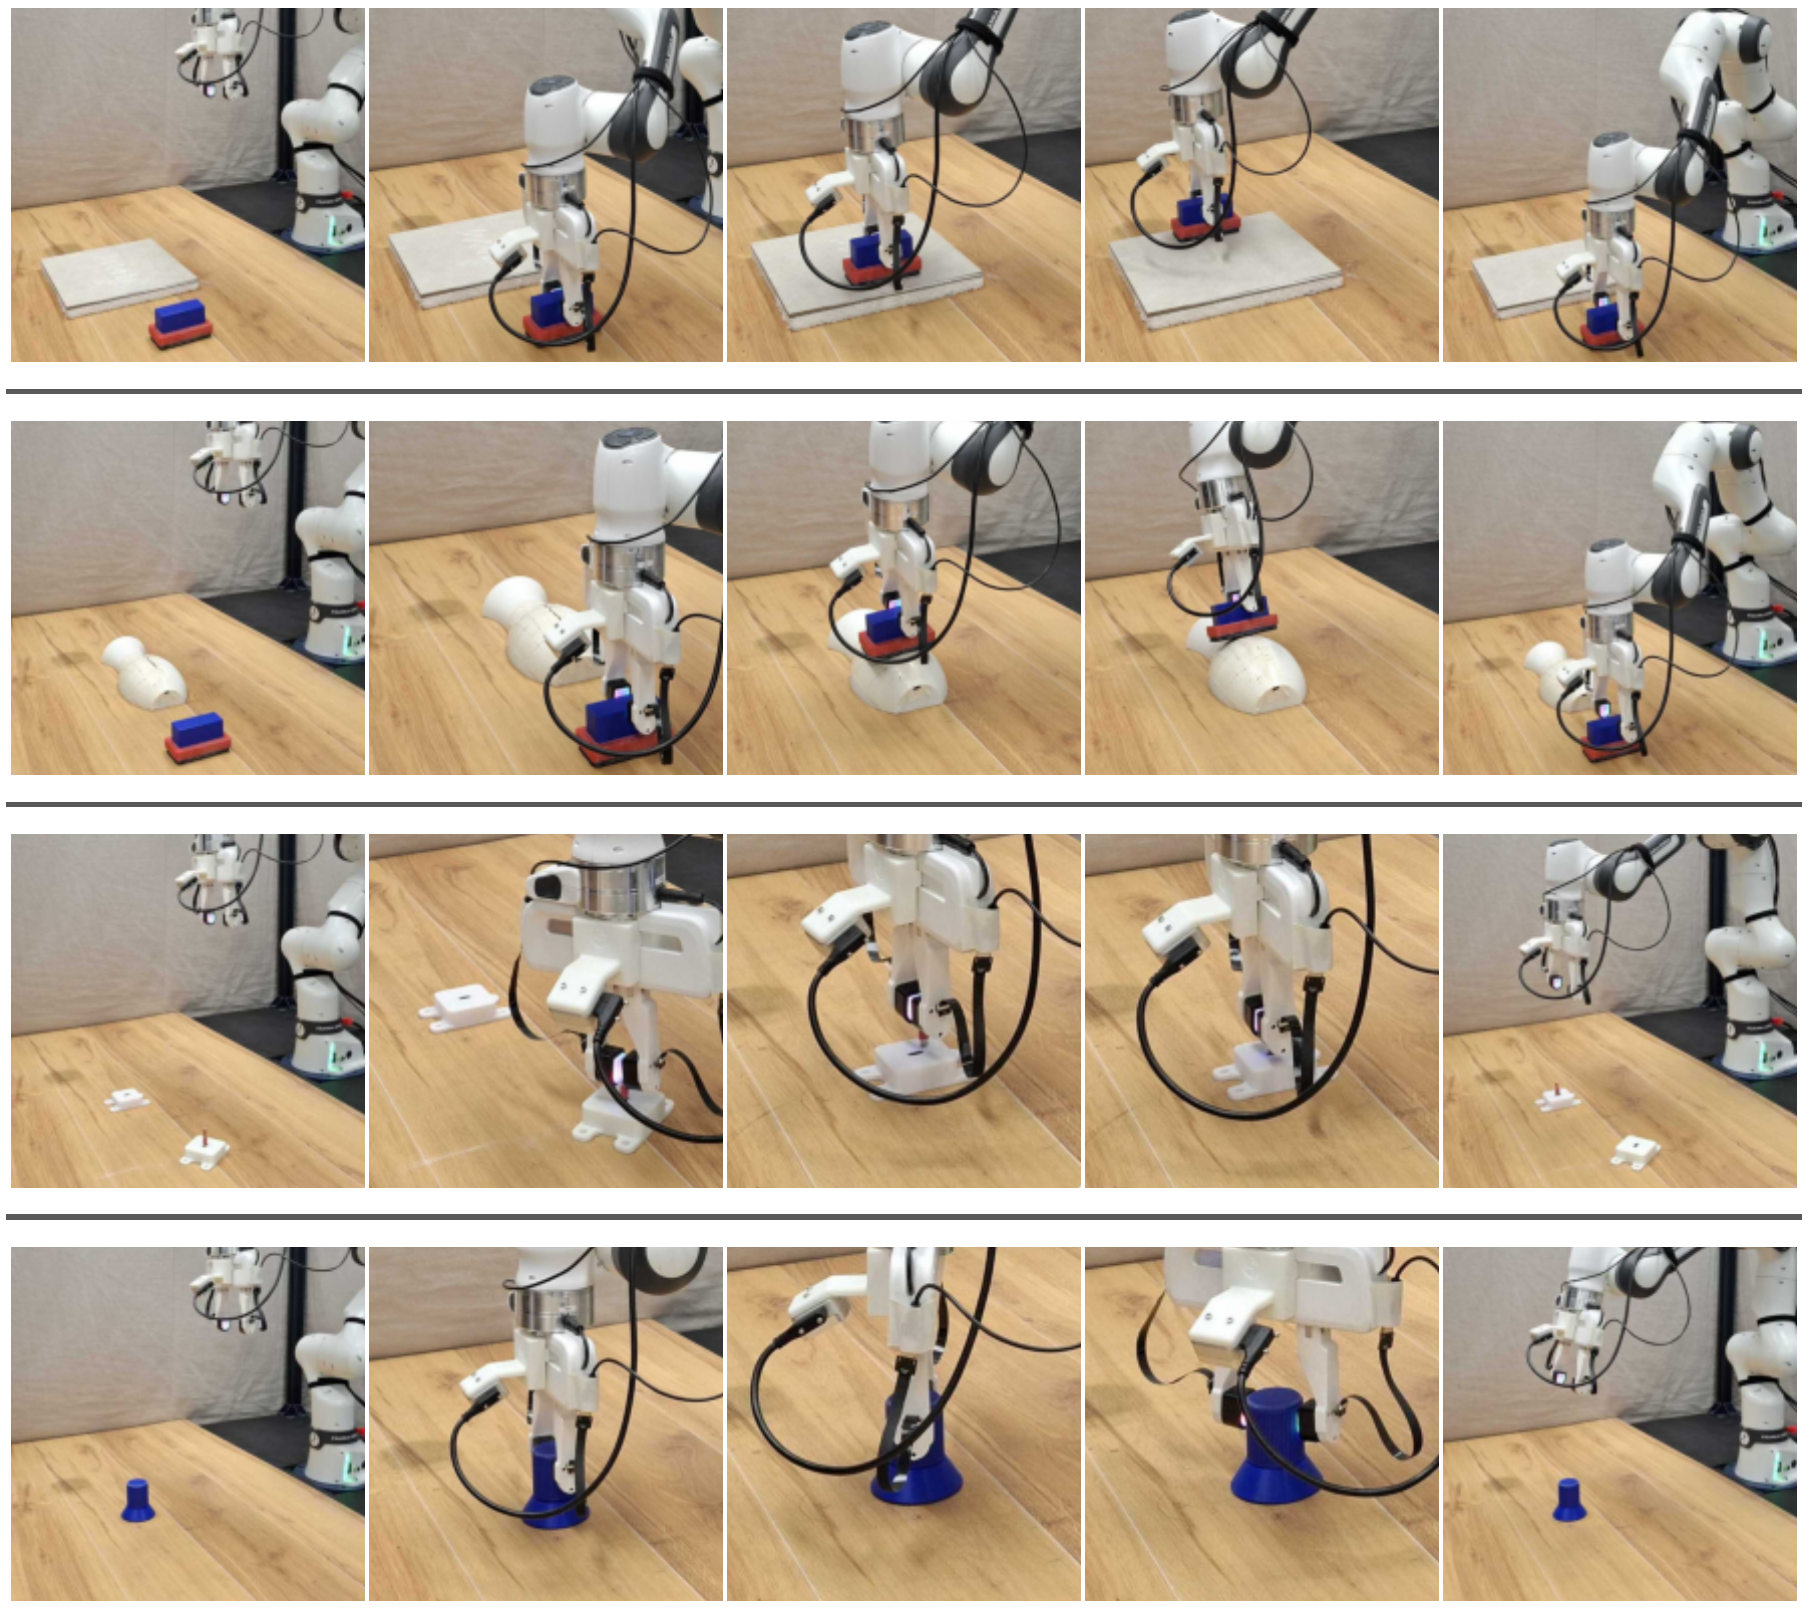
TACTIC: Understanding Tactile Encoders and Conditioning for Contact-rich Robot Manipulation Policies Seongjin Bien*, Débora Oliveira*, Carlo Kneissl, Reihaneh Mirjalili, Pahnkuri Vanjani, Rudolf Lioutikov, Gitta Kutyniok, Florian Walter, Wolfram Burgard arXiv, 2026 |
|
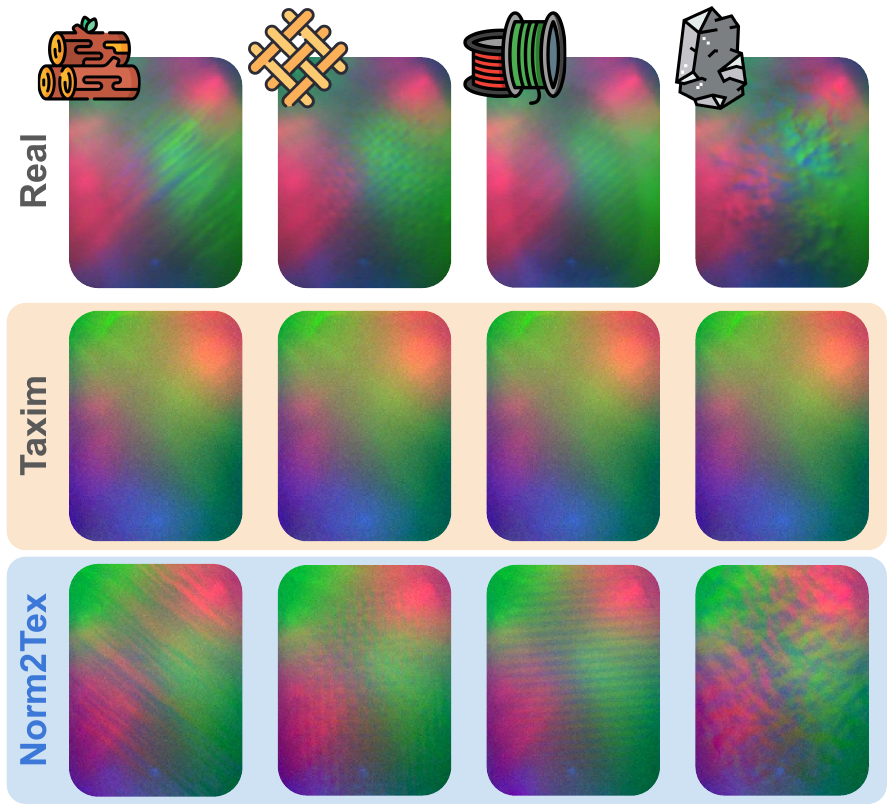
Norm2Tex: Augmenting Visuo-Tactile Simulations with Texture Seongjin Bien*, Débora Oliveira*, Roberto Calandra, Florian Walter, Wolfram Burgard arXiv, 2026 |
|
MetricNet: Recovering Metric Scale in Generative Navigation Policies Abhijeet Nayak*, Débora Oliveira*, Samiran Gode*, Cordelia Schmid, Wolfram Burgard Accepted to International Conference on Robotics & Automation (ICRA), 2026 |
|
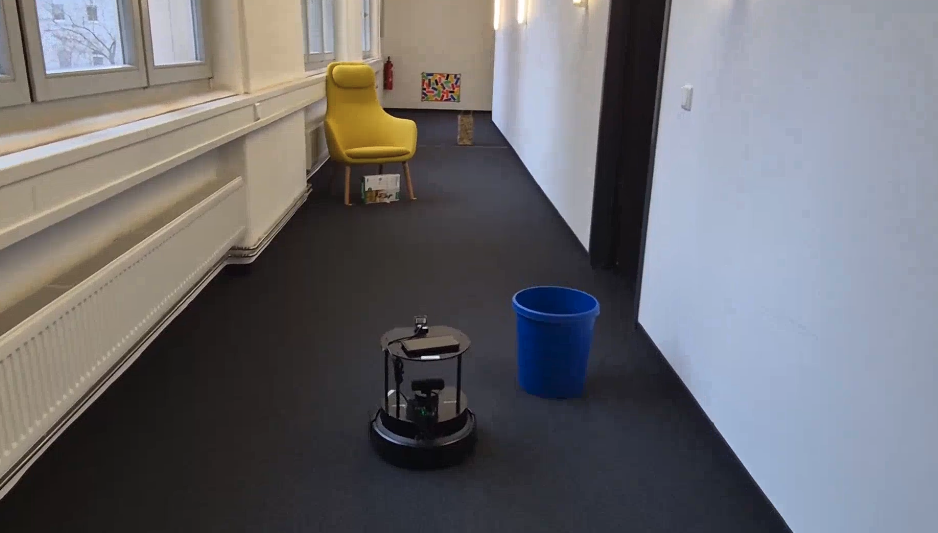
FlowNav: Combining Flow Matching and Depth Priors for Efficient Navigation Samiran Gode*, Abhijeet Nayak*, Débora Oliveira*, Cordelia Schmid, Wolfram Burgard Accepted to International Conference on Intelligent Robots and Systems (IROS), 2025 |
|
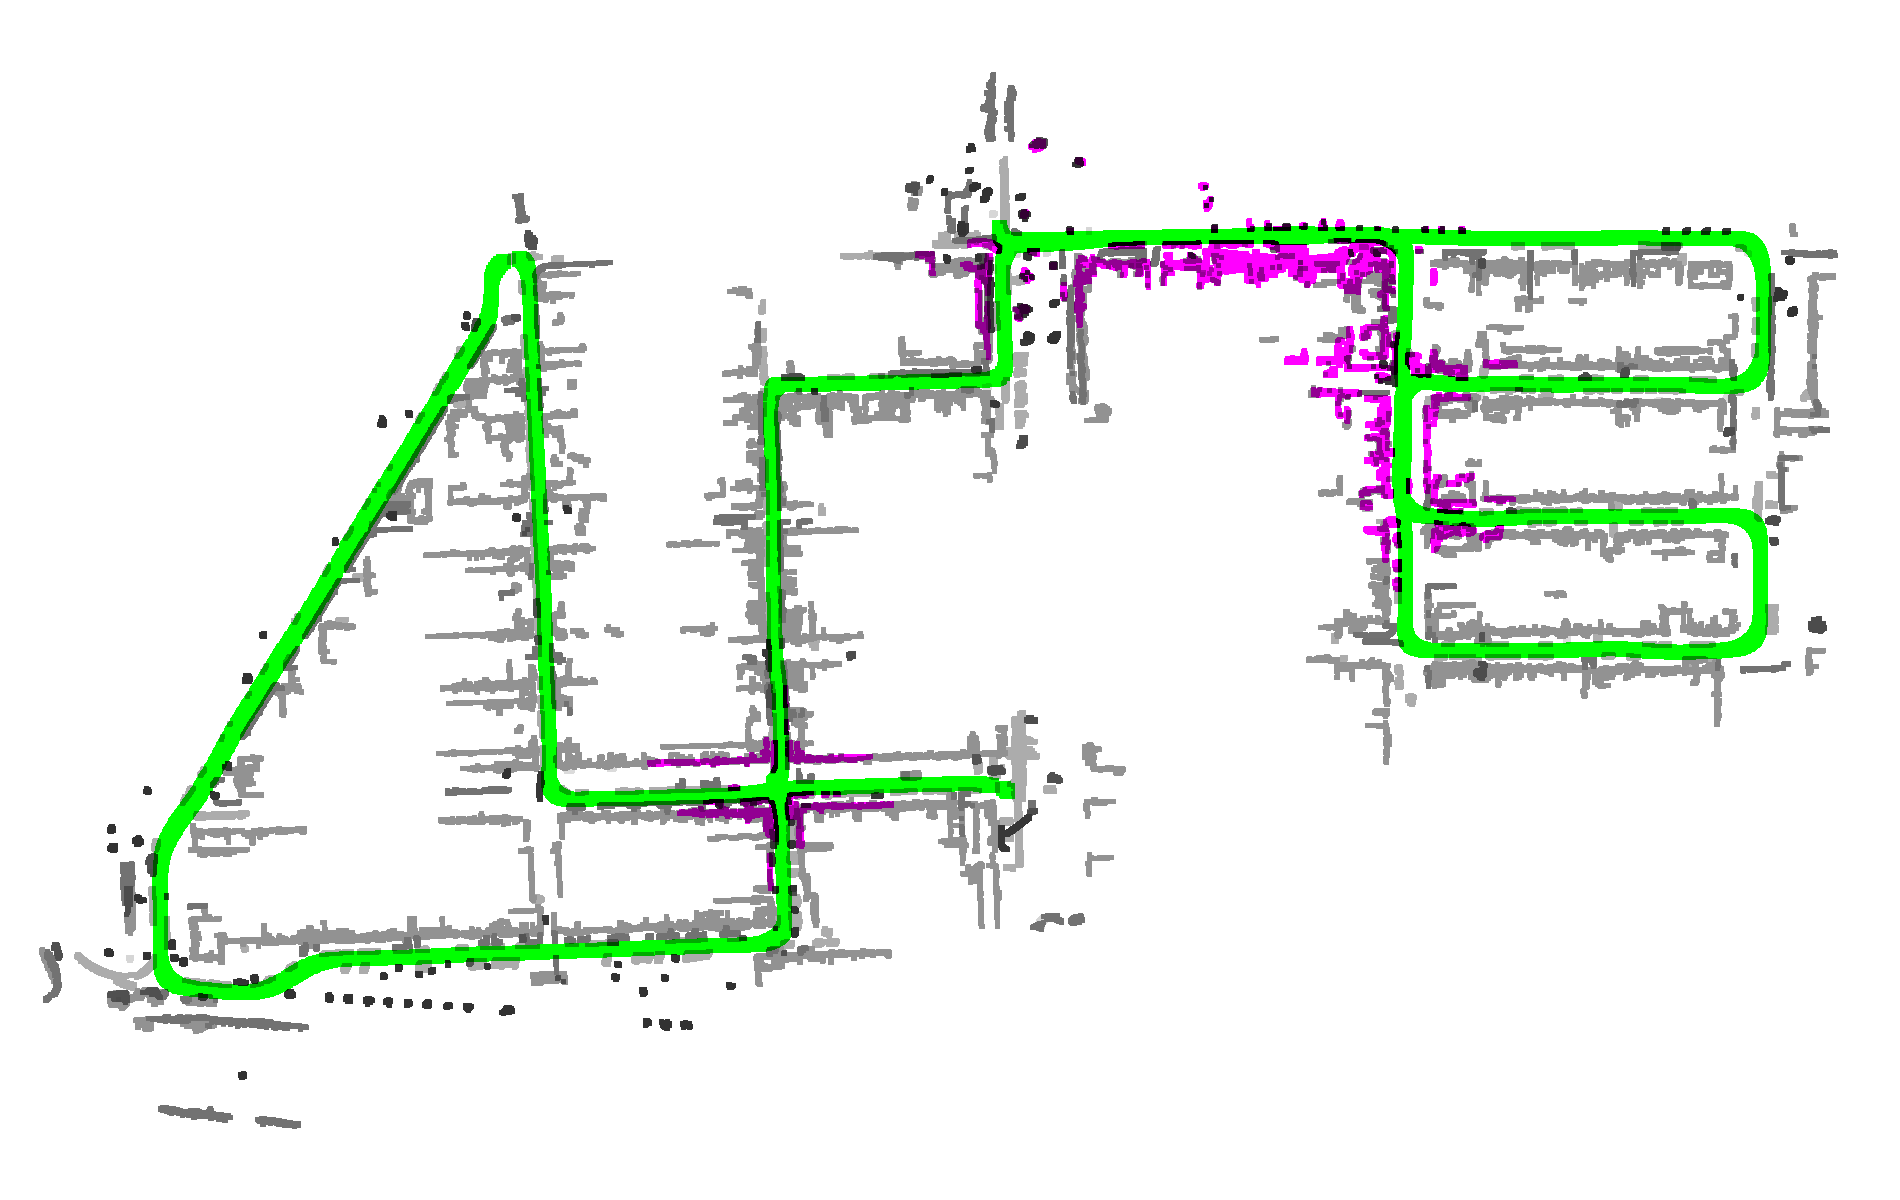
REGRACE: A Robust and Efficient Graph-based Re-localization Algorithm using Consistency Evaluation Débora Oliveira*, Joshua Knights*, Sebastián Barbas Laina*, Simon Boche*, Wolfram Burgard, Stefan Leutenegger Accepted to International Conference on Intelligent Robots and Systems (IROS), 2025 |
|
Optical tracking system based on COTS components Débora Oliveira*, Marcos Morais, Antonio Marcus Lima Accepted to International Conference on Image Processing Applications and Systems (IPAS), 2022 |
|
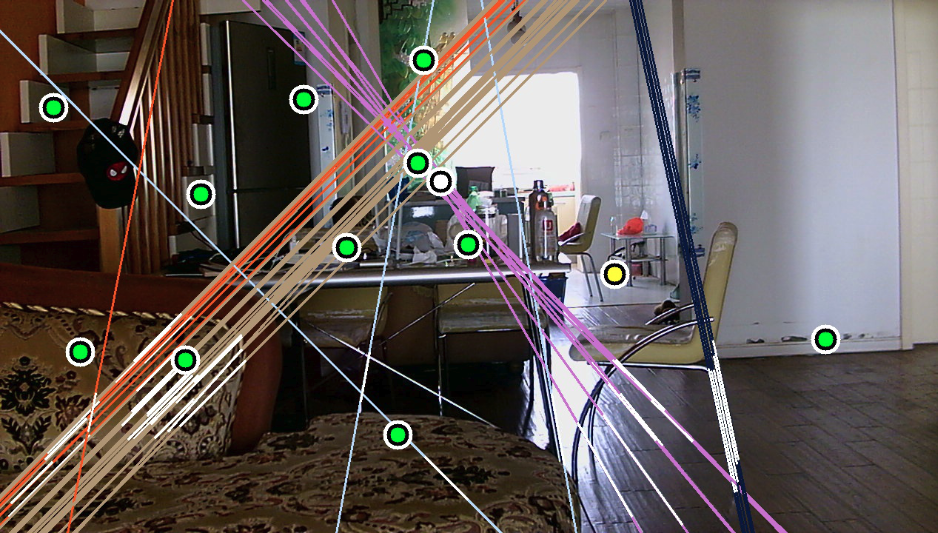
Void detection for UAV based on optical flow and vanishing points Débora Oliveira*, Marcos Morais, Antonio Marcus Lima Accepted to Brazilian Symposium on Intelligent Automation (SBAI), 2021 (Honorable Mention) |
|
Inspired by Jon Barron |